
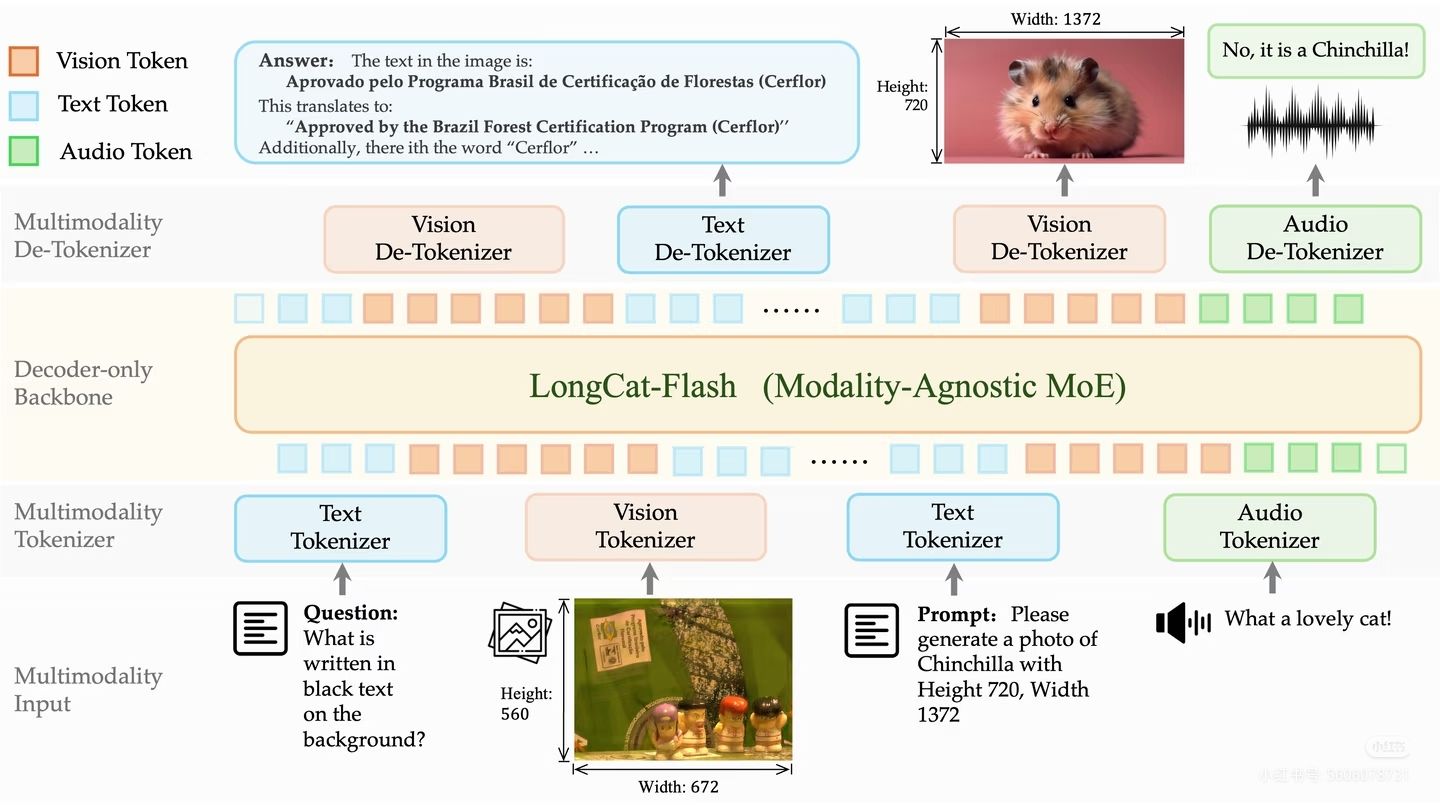
Meituan Open Sources LongCat-Next: A Native Multimodal Model Designed for Physical World AI Interaction
Meituan's technical team has officially announced the release and open-sourcing of LongCat-Next, a pioneering native multimodal model. This release marks a significant step in Meituan's exploration of "Physical AI," where vision and speech are integrated as native components rather than secondary inputs. By open-sourcing the core model alongside its discrete tokenizer, Meituan aims to provide the global developer community with the essential tools to build AI systems capable of perceiving, understanding, and interacting with the real world. The project emphasizes a shift toward AI that treats sensory data as a primary language, potentially transforming how machines navigate and function within physical environments. This strategic move highlights Meituan's commitment to fostering an open ecosystem for advanced multimodal research and practical AI applications.
Key Takeaways
- Native Multimodal Integration: LongCat-Next treats vision and speech as "native languages," moving away from traditional additive multimodal approaches.
- Open Source Commitment: Meituan has open-sourced the LongCat-Next model and its specialized discrete tokenizer to the developer community.
- Focus on Physical AI: The model is specifically designed to bridge the gap between digital intelligence and physical world perception and action.
- Developer Empowerment: The release aims to enable the creation of AI that can truly perceive, understand, and act within real-world environments.
In-Depth Analysis
The Vision of Physical AI: Perception and Action
LongCat-Next represents a strategic pivot toward what Meituan terms "Physical World AI." Unlike traditional large language models that primarily operate within the confines of text-based data, LongCat-Next is built to address the complexities of the tangible environment. The core objective of this research is to move beyond simple data processing and toward a model that can "perceive, understand, and act."
By focusing on the physical world, Meituan is targeting the next frontier of artificial intelligence: the ability for machines to navigate and interact with their surroundings in a meaningful way. This involves a deep integration of sensory inputs, allowing the AI to interpret visual cues and auditory signals with the same level of fluency that previous models applied to text. The emphasis on "action" suggests that LongCat-Next is not merely an analytical tool but a foundational framework for robotics and autonomous systems that require real-time environmental engagement.
Native Multimodality: Vision and Speech as Primary Languages
A defining characteristic of LongCat-Next is its "native" approach to multimodality. In many existing AI architectures, vision and speech are treated as external modules that are translated into a format the central model can understand. Meituan’s approach challenges this by treating these sensory modalities as the AI's "mother tongues."
This native integration is facilitated by the release of a discrete tokenizer. Tokenization is the process of breaking down data into manageable parts for the model to process. By providing a discrete tokenizer specifically designed for this multimodal framework, Meituan ensures that visual and auditory information is processed with high fidelity and structural consistency. This allows the model to maintain the nuances of physical world data, leading to a more holistic understanding of the environment. When vision and speech are native to the model, the latency and information loss often associated with translation layers are significantly reduced, paving the way for more responsive and accurate AI behavior.
Empowering the Ecosystem Through Open Source
By open-sourcing the core research ideas, the LongCat-Next model, and the discrete tokenizer, Meituan is positioning itself as a key contributor to the open AI ecosystem. The decision to share these tools reflects a belief that the path to truly capable physical AI requires collaborative effort across the industry.
For developers, the availability of the LongCat-Next model and its tokenizer lowers the barrier to entry for multimodal research. It provides a standardized starting point for building applications that require a sophisticated understanding of the physical world. This open-source strategy not only accelerates the pace of innovation but also allows for diverse use cases that Meituan’s internal team might not have initially envisioned. By providing the "research ideas" alongside the code, Meituan is offering a transparent look into their methodology, encouraging others to build upon and refine their approach to native multimodality.
Industry Impact
The release of LongCat-Next is likely to influence the industry's approach to multimodal AI development. As more companies seek to move AI out of the cloud and into physical devices—such as delivery robots, smart hardware, and autonomous vehicles—the demand for native multimodal frameworks will grow. Meituan’s contribution sets a precedent for treating non-textual data as a primary input, which could lead to a standardization of how vision and speech are tokenized and processed across the industry. Furthermore, by open-sourcing these high-level tools, Meituan is challenging other tech giants to be equally transparent, potentially leading to a more collaborative and faster-moving AI research landscape focused on real-world utility.
Frequently Asked Questions
Question: What makes LongCat-Next different from other multimodal models?
LongCat-Next is designed as a "native" multimodal model, meaning it treats vision and speech as primary languages rather than secondary inputs. This allows for a more direct and integrated understanding of the physical world compared to models that rely on external translation layers for different types of data.
Question: What specific components has Meituan open-sourced?
Meituan has open-sourced the core LongCat-Next model, the research ideas behind its development, and its discrete tokenizer. These components are intended to help developers build AI systems that can perceive and act in real-world scenarios.
Question: What is the primary goal of the LongCat-Next project?
The primary goal is to explore the path toward "Physical World AI." Meituan aims to create a framework where AI can move beyond digital data to perceive, understand, and interact effectively with the physical environment.